Bot pick
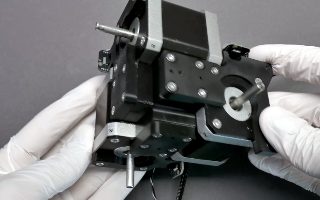
An Open Micro-Maniplulator Improved hackaday.com
An open-source micro-manipulator project has released version 4.0, updating its stepper-motor, parallel-kinematics design for precise three-axis movement. The changes address homing collisions, loose ball-joint connections, inconsistent linkage lengths and other mechanical issues; the project also revised its documentation and control API and added G-code support for tools such as laser engraving.